7.1.1.3 PtPositioningDriveAxisType
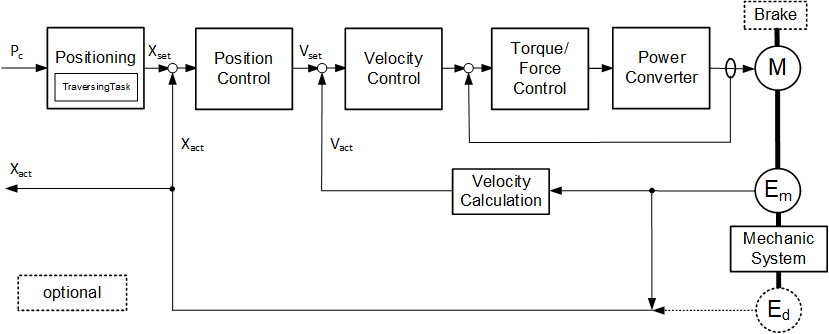
A PtPositioningDriveAxisType is an PtDriveAxisType representing the functionality of a servo drive or stepper drive with a motion trajectory command interface. Figure 11 shows a block diagram demonstrating the basic organization and control flow for this axis type.
The formal definition of the PtPositioningDriveAxisType ObjectType can be found in Table 25.
| Attribute | Value | ||||
| BrowseName | PtPositioningDriveAxisType | ||||
| IsAbstract | False | ||||
| References | Node Class | BrowseName | DataType | TypeDefinition | Other |
|---|---|---|---|---|---|
| Subtype of the PtDriveAxisType. | |||||
| 0:HasComponent | Object | Homing | 0:FolderType | M | |
| 0:HasComponent | Object | CharacteristicsMechanics | 0:FolderType | O | |
| 0:HasComponent | Object | VelocityProfile | 0:FolderType | M | |
| 0:HasComponent | Object | LimitSupervision | 0:FolderType | M | |
| 0:HasComponent | Object | Monitoring | 0:FolderType | M | |
| 0:HasComponent | Object | CharacteristicsMotorAndControl | 0:FolderType | M | |
| 0:HasComponent | Object | MotionProgram | 0:FileType | O | |
| 0:GeneratesEvent | ObjectType | PtTorqueForceLimitEventType | |||
| 0:GeneratesEvent | ObjectType | PtMotorCurrentLimitEventType | |||
| Conformance Units | |||||
|---|---|---|---|---|---|
| Powertrain Actual and Command Values | |||||
| Powertrain Axis Properties | |||||
| Powertrain Limit Events |
Some components of the PtPositioningDriveAxisType have additional subcomponents which are defined in Table 26.
| BrowsePath | References | NodeClass | BrowseName | DataType | TypeDefinition | Others |
| Monitoring | 0:HasComponent | Variable | PositionActualValue | 0:Double | 0:AnalogUnitType | M, RO |
| Monitoring | 0:HasComponent | Variable | PositionCommandValue | 0:Float | 0:AnalogUnitType | O, RO |
| Monitoring | 0:HasComponent | Variable | PositionSetpoint | 0:Float | 0:AnalogUnitType | O, RO |
| Monitoring | 0:HasComponent | Variable | VelocityActualValue | 0:Float | 0:AnalogUnitType | M, RO |
| Monitoring | 0:HasComponent | Variable | VelocitySetpoint | 0:Float | 0:AnalogUnitType | O, RO |
| Monitoring | 0:HasComponent | Variable | AccelerationActualValue | 0:Float | 0:AnalogUnitType | O, RO |
| Monitoring | 0:HasComponent | Variable | AccelerationSetpoint | 0:Float | 0:AnalogUnitType | O, RO |
| Monitoring | 0:HasComponent | Variable | TorqueForceSetpoint | 0:Float | 0:AnalogUnitType | O, RO |
| Monitoring | 0:HasComponent | Variable | TorqueForceCommandAdditiveValue | 0:Float | 0:AnalogUnitType | O, RO |
| Monitoring | 0:HasComponent | Variable | <EncoderxTemperature> | 0:Float | PtTemperatureVariableType | OP, RO |
| Monitoring | 0:HasComponent | Variable | PositionFollowingError | 0:Float | 0:AnalogUnitType | O, RO |
| Monitoring | 0:HasComponent | Variable | VelocityFollowingError | 0:Float | 0:AnalogUnitType | O, RO |
| Monitoring | 0:HasComponent | Object | TraversingTask | PtTraversingTaskType | M | |
| Monitoring | 0:HasComponent | Variable | Override | 0:Float | 0:BaseDataVariableType | O, RO |
| Monitoring | 0:HasComponent | Variable | HomingState | 0:UInt16 | PtHomingStateVariableType | M, RO |
| LimitSupervision | 0:HasComponent | Variable | MotorCurrentLimitHigh | 0:Float | 0:AnalogUnitType | M, RO |
| LimitSupervision | 0:HasComponent | Variable | TorqueLimit | 0:Float | 0:AnalogUnitType | O, RO |
| LimitSupervision | 0:HasComponent | Variable | TorqueLimitLow | 0:Float | 0:AnalogUnitType | O, RO |
| LimitSupervision | 0:HasComponent | Variable | TorqueLimitHigh | 0:Float | 0:AnalogUnitType | O, RO |
| LimitSupervision | 0:HasComponent | Variable | SoftwarePosLimitLow | 0:Float | 0:AnalogUnitType | M, RO |
| LimitSupervision | 0:HasComponent | Variable | SoftwarePosLimitHigh | 0:Float | 0:AnalogUnitType | M, RO |
| LimitSupervision | 0:HasComponent | Variable | TorqueLimiting | 0:Boolean | 0:BaseDataVariableType | O, RO |
| CharacteristicsMotorAndControl | 0:HasComponent | Variable | TimePeriodVelocityControl | 0:Float | 0:AnalogUnitType | O, RO |
| CharacteristicsMotorAndControl | 0:HasComponent | Variable | TimePeriodTrajectoryInterpolation | 0:Float | 0:AnalogUnitType | O, RO |
| CharacteristicsMotorAndControl | 0:HasComponent | Variable | TimePeriodPositionControl | 0:Float | 0:AnalogUnitType | O, RO |
| CharacteristicsMotorAndControl | 0:HasComponent | Variable | TimePeriodTorqueControl | 0:Float | 0:AnalogUnitType | O, RO |
| CharacteristicsMotorAndControl | 0:HasComponent | Variable | TrajectoryInterpolationMode | 0:Byte | 0:MultiStateValueDiscreteType | O, RO |
| Homing | 0:HasComponent | Variable | HomingDirection | 0:UInt16 | PtHomingDirectionVariableType | O, RO |
| Homing | 0:HasComponent | Variable | HomingSpeedToCam | 0:Float | 0:AnalogUnitType | O, RO |
| Homing | 0:HasComponent | Variable | HomingSpeedToMark | 0:Float | 0:AnalogUnitType | O, RO |
| Homing | 0:HasComponent | Variable | HomingPointOffset | 0:Float | 0:AnalogUnitType | O, RO |
| Homing | 0:HasComponent | Variable | HomingMode | 0:UInt16 | PtHomingModeVariableType | M, RO |
| CharacteristicsMechanics | 0:HasComponent | Variable | GearFactorPrecise | PtGearFactorDataType | 0:BaseDataVariableType | O, RO |
| CharacteristicsMechanics | 0:HasComponent | Variable | GearRatio | 0:Float | 0:BaseDataVariableType | O, RO |
| CharacteristicsMechanics | 0:HasComponent | Variable | SpindlePitch | 0:Float | 0:BaseDataVariableType | O, RO |
| VelocityProfile | 0:HasComponent | Variable | JogPosInc1 | 0:Float | 0:AnalogUnitType | O, RO |
| VelocityProfile | 0:HasComponent | Variable | JogPosInc2 | 0:Float | 0:AnalogUnitType | O, RO |
The SpindlePitch Variable shall be provided if a spindle is present in the Powertrain Axis Object.
The child Nodes of the PtPositioningDriveAxisType have additional Attribute values defined in Table 27.
| BrowsePath | Value Attribute | |||
| [ { "Value":0, "DisplayName": "LINEAR", "Description": "Linear trajectory interpolation" }, { "Value":1, "DisplayName": "VENDOR_SPECIFIC", "Description": "Vendor specific trajectory interpolation" } ]
|
For a description of the Variables see Table 54.