7.1.1.2 PtVelocityDriveAxisType
The PtVelocityDriveAxisType is an PtDriveAxisType representing the functionality of a VSD with a speed command interface. Figure 10 shows a block diagram demonstrating the basic organization and control flow for this axis type.
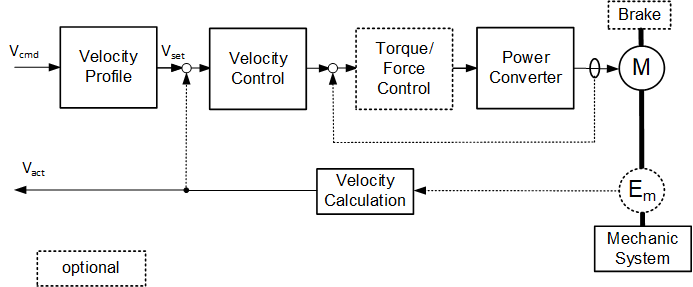
The formal definition of the PtVelocityDriveAxisType ObjectType can be found in Table 23.
| Attribute | Value | ||||
| BrowseName | PtVelocityDriveAxisType | ||||
| IsAbstract | False | ||||
| References | Node Class | BrowseName | DataType | TypeDefinition | Other |
|---|---|---|---|---|---|
| Subtype of the PtDriveAxisType. | |||||
| 0:HasComponent | Object | VelocityProfile | 0:FolderType | M | |
| 0:HasComponent | Object | CharacteristicsMechanics | 0:FolderType | O | |
| 0:GeneratesEvent | ObjectType | PtTorqueForceLimitEventType | |||
| 0:GeneratesEvent | ObjectType | PtMotorCurrentLimitEventType | |||
| 0:HasComponent | Object | Monitoring | 0:FolderType | M | |
| 0:HasComponent | Object | CharacteristicsMotorAndControl | 0:FolderType | M | |
| 0:HasComponent | Object | LimitSupervision | 0:FolderType | O | |
| Conformance Units | |||||
|---|---|---|---|---|---|
| Powertrain Actual and Command Values | |||||
| Powertrain Axis Properties | |||||
| Powertrain Limit Events |
The components of the PtVelocityDriveAxisType have additional subcomponents which are defined in Table 24.
| BrowsePath | References | NodeClass | BrowseName | DataType | TypeDefinition | Others |
| Monitoring | 0:HasComponent | Variable | VelocitySetpoint | 0:Float | 0:AnalogUnitType | M, RO |
| Monitoring | 0:HasComponent | Variable | VelocityCommandValue | 0:Float | 0:AnalogUnitType | M, RO |
| Monitoring | 0:HasComponent | Variable | VelocityCommandAdditiveValue | 0:Float | 0:AnalogUnitType | O, RO |
| Monitoring | 0:HasComponent | Variable | VelocityActualValue | 0:Float | 0:AnalogUnitType | M, RO |
| Monitoring | 0:HasComponent | Variable | AccelerationSetpoint | 0:Float | 0:AnalogUnitType | O, RO |
| Monitoring | 0:HasComponent | Variable | AccelerationCommandAdditiveValue | 0:Float | 0:AnalogUnitType | O, RO |
| Monitoring | 0:HasComponent | Variable | AccelerationActualValue | 0:Float | 0:AnalogUnitType | O, RO |
| Monitoring | 0:HasComponent | Variable | PositionActualValue | 0:Double | 0:AnalogUnitType | O, RO |
| Monitoring | 0:HasComponent | Variable | TorqueForceSetpoint | 0:Float | 0:AnalogUnitType | O, RO |
| Monitoring | 0:HasComponent | Variable | TorqueForceCommandAdditiveValue | 0:Float | 0:AnalogUnitType | O, RO |
| Monitoring | 0:HasComponent | Variable | <EncoderxTemperature> | 0:Float | PtTemperatureVariableType | OP, RO |
| Monitoring | 0:HasComponent | Variable | VelocityFollowingError | 0:Float | 0:AnalogUnitType | O, RO |
| CharacteristicsMotorAndControl | 0:HasComponent | Variable | TimePeriodVelocityControl | 0:Float | 0:AnalogUnitType | O, RO |
| CharacteristicsMotorAndControl | 0:HasComponent | Variable | TimePeriodTorqueControl | 0:Float | 0:AnalogUnitType | O, RO |
| CharacteristicsMechanics | 0:HasComponent | Variable | GearFactorPrecise | PtGearFactorDataType | 0:BaseDataVariableType | O, RO |
| CharacteristicsMechanics | 0:HasComponent | Variable | GearRatio | 0:Float | 0:BaseDataVariableType | O, RO |
| LimitSupervision | 0:HasComponent | Variable | TorqueLimit | 0:Float | 0:AnalogUnitType | O, RO |
| LimitSupervision | 0:HasComponent | Variable | TorqueLimitLow | 0:Float | 0:AnalogUnitType | O, RO |
| LimitSupervision | 0:HasComponent | Variable | TorqueLimitHigh | 0:Float | 0:AnalogUnitType | O, RO |
| VelocityProfile | 0:HasComponent | Variable | VelocityRampUpTime | 0:Float | 0:AnalogUnitType | O, RO |
| VelocityProfile | 0:HasComponent | Variable | VelocityRampAcceleration | 0:Float | 0:AnalogUnitType | O, RO |
For a description of the Variables see Table 54.